Site Capture for Robot Commissioning
Robots arrive at a site that has only been drawn, and every layout change afterwards breaks their map.
What it does
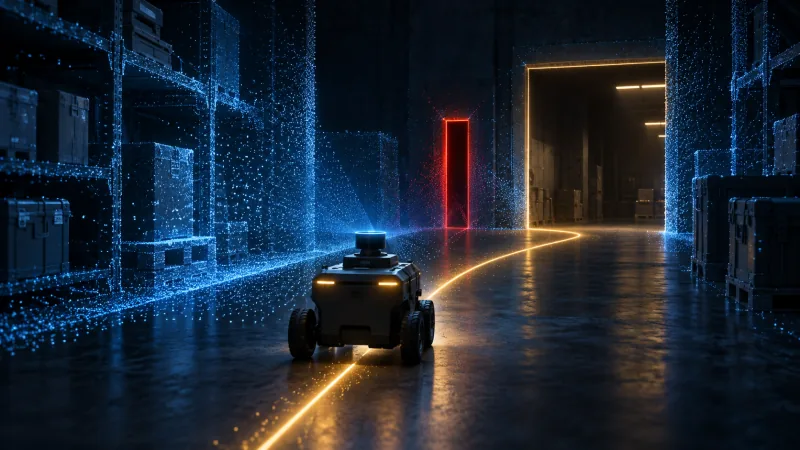
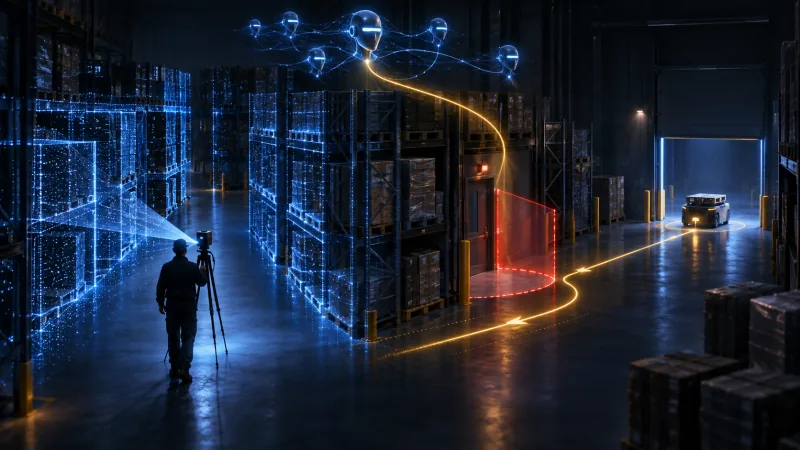
The site captured to a measured model before the first robot arrives: aisles, doors, docks, clearances and the places people walk. The robots’ maps are built from it, and when the layout changes the change is captured and the maps updated, instead of the fleet being re-taught by hand.
Capabilities
- The site captured before the first robot arrives
- Clearances and pedestrian routes measured, not assumed
- Robot maps built from the measured model
- Layout changes captured and the maps updated
In use
In practice
- FebruaryThe system · The building captured to a measured model in an afternoon
- FebruaryWhat happened · Two aisles narrower than the drawing; a fire door opens into the route
- FebruaryA person · The engineer moves the route before any robot arrives
- MayThe system · A new rack line captured in one pass; the maps updated overnight
- MayThe outcome · The fleet works the new layout the next morning
A warehouse is to receive its first autonomous trucks in March. In February the building is captured in an afternoon, and the model shows two aisles narrower than the drawing and a fire door that opens into the planned route. The route is moved before a single robot is delivered. In May a new rack line goes in, and one capture pass updates the maps overnight.
Built from